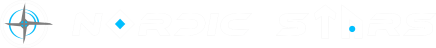
1 Steady segments: which seconds count
Nothing is measured while the boat is manoeuvring, drifting or reaching. The report measures steady segments — stretches where the boat was settled on one board in one mode — and every point on every chart is one segment.
The detector is the same one the guided calibration uses:
| Rule | Value | Why |
|---|---|---|
| Upwind band | 25–65° true wind angle | Close-hauled sailing, either board. |
| Downwind band | 120–175° | Broad reaching and running. |
| Boat-speed floor | 2 knots | Below it the wind instruments are not measuring sailing. |
| Minimum run | 10 seconds | A shorter excursion is noise, not a change of board. |
| Maximum manoeuvre | 60 seconds | Longer than this and it is not one tack or gybe. |
| Margin trimmed each side | 15 seconds | The boat is still accelerating out of a tack and still slowing into one. |
| Minimum segment | 30 seconds | Shorter than this, a median over the segment is one gust. |
Every value inside a segment is read through the boat’s calibration lens and its upwash table, at read time. A correction entered after the regatta therefore moves the numbers in the report, which is the point of a lens.
A segment is reduced to medians, never means: its median true wind speed becomes the point’s position on the x axis, and its median value of whatever is being plotted becomes the y. A median resists a single gust; a mean does not.
2 The three metrics
The first three panels of an XY report all measure the same thing — distance from the boat’s own target — in three different units.
Read as a sentence: how much faster the boat went than the polar says it should have at the angle it actually sailed, how much wider or narrower it sailed than the best angle, and how much of the available progress upwind or downwind it made.
The target and the optimum both come from the boat’s polar: the active perf source when the boat has one, otherwise the active nav source. Every report states which role acted as its yardstick, because the same boat’s numbers change the day a performance sheet is uploaded.
The optimum angle is the best populated cell of the polar’s own grid, not a sweep of the interpolated surface. Table polars store the beat and run angles as their own wind-angle rows and the surface between them is flat, so sweeping the surface returns an angle the sheet never claimed.
3 The covariates
The second part of the report plots what the boat was doing while it produced those numbers: boat speed, true wind angle, heel, rudder angle, forestay load and fore-and-aft trim, each against true wind speed. Each is summarised per segment as a median with its median absolute deviation, so a channel that is stuck or intermittent shows a spread that gives it away.
Angles are reduced with circular statistics — the circular median of the heading, and leeway as the wrapped difference between heading and course over ground. Averaging 359° and 1° arithmetically gives 180°, which is the wrong way round the compass.
Behind each covariate the report draws the boat’s own target for that quantity, read off its tuning table or its polar. Where the table has no column for a quantity, no target curve is drawn and the panel says so: an absent target is a fact about the tuning sheet, not a gap to interpolate across.
4 The smoother
A day produces thirty to sixty segments. Drawn as a scatter they are unreadable; drawn as a straight line they claim a linear relationship nobody measured. The report draws a locally weighted regression — LOESS — evaluated on a fixed wind-speed grid.
At each grid point:
Read as a sentence: each point of the curve is a small straight-line fit through the segments sailed in a similar breeze, with the nearer and longer segments counting for more.
Local linear rather than local mean, because a local mean bends away from the truth at the ends of the range, where every curve is already least supported. The tricube kernel is the standard choice: it reaches zero smoothly at the edge of the span, so a segment entering or leaving the window does not step the curve.
Weighting by scored seconds rather than by segment count means a four-minute beat counts for more than a thirty-second one. The span widens where the day is thin and narrows where it is dense, so a curve follows real structure where there is evidence for it and flattens where there is not, rather than inventing detail.
5 The gate, and the fade
Each grid point carries an effective sample size — the kernel’s own weight, not the panel’s total count. Below the trend gate the grid point is not emitted at all, so a day spent in a three-knot band produces a curve over that band and nothing either side. A series with too few segments produces no curve at all and says why; a quantile band needs a minimum number of populated wind bins.
Where a curve exists but is thinly supported, the renderer fades it: the drawn opacity falls with the summed kernel weight at that point. Fading is a drawing hint about a curve that passed its gate — it is not a substitute for the gate.
Every series prints the number of segments behind it. A series below its gate prints no number at all rather than a zero, because “we looked and found none” and “there was not enough to look” are different answers.
6 The uncertainty band
Around each trend the report draws an approximate 95 % band from a day-clustered bootstrap: whole sailing days are resampled with replacement, the smoother is re-run on each resample, and the band is the 2.5th and 97.5th percentiles of the resulting curves at each grid point.
Clustering by day rather than by segment is the part that matters. Segments from one day share a sea state, a rig tune, a crew and one set of instrument errors, so treating them as independent samples would report a band several times narrower than the evidence supports. The resampling is seeded, so the same inputs produce the same band.
Where too few days or too few points are available, no band is estimated. The trend is still drawn; the band is simply absent rather than enormous, and it is never bridged across the grid points where the estimate failed.
7 The fastest and slowest quartiles
This is the layer that turns a scatter into a setting. The report’s segments are ranked by VMG percentage and split at the quartiles. For each covariate it then shades two regions across wind speed: the interquartile range of that covariate over the fastest quarter of the segments, and over the slowest quarter.
Read as a sentence: what the boat was set to when it went well, against what it was set to when it did not, at the same wind speed.
If the two regions separate — less rudder and more forestay load in the fast quarter, say — the page has said something about the setup. If they overlap, they overlap, and the reading is that this covariate did not distinguish the fast sailing from the slow.
Quartiles rather than terciles or deciles: terciles blunt the contrast, and deciles leave single segments deciding a shaded region. The split is within the report’s own scope, so “fastest” means fastest on this day in this mode — not against a fleet and not against the boat’s history.
8 The season reference
Behind each series the report can draw the same trend over a wider window, dashed: the boat’s own 365 days ending at the report’s day, computed with the same segmentation, the same metrics and the same smoother.
A rolling window rather than a named season, because a window needs no object to exist and no crew to maintain one. It is the reference that answers “is this normal for us?”, which is a different question from “is this on target?” — the solid line answers the second.
The season layer is the expensive half of a report. A day is one day and a season is 366 of them, so the first read of a report with a season reference often returns the day’s own panels complete and the season layer still computing; the page asks again and it fills in.
9 What the numbers were measured against
A percentage of target is meaningless without the target, and the target moves: a polar re-upload, a calibration entry, an upwash row. Every report therefore prints its yardstick — the polar source and its role, when it was uploaded, how many calibration entries and upwash rows were in force, the version of the computation, and a fingerprint of the telemetry it read.
10 Named limits
Every report carries the limits that apply to it. The standing ones:
- Reaching is not measured. Only the two mode bands are segmented.
- A missing channel is a missing panel. Coverage is reported per channel, as seconds and as a share of the report’s steady sailing, whether the channel was logged or not.
- Small samples are common. Thirty to sixty segments split four ways by leg leaves cells of two, which is what the gates exist for.
- Panels are scaled to the trend, not to the outliers. A panel scaled to its widest point spends its height on one segment, so the drawn range follows the curves and the bands, and the number of points falling outside it is printed under the page.
- The report models the boat, not the day. Sea state, crew, rig tune, sail age and a team simply getting better are all real and none of them is in these numbers.
For how to open, read and print a report, see Performance reports.